SR&ED Case Study: Robotics and Industrial Automation

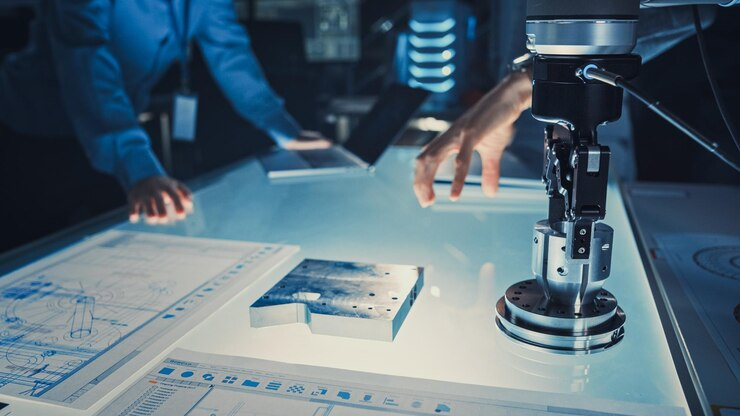
Futuristic-robotic-arm-picking-up-a-metal-object

Background

A manufacturer wanted to automate a part-handling process currently done manually because the parts varied significantly in shape and orientation from batch to batch. Standard pick-and-place robotic systems, designed for uniform parts, could not reliably grip or orient the variable parts.

The Challenge

It was unclear whether any combination of gripper design, vision guidance, and motion planning could reliably handle the part variability at the required production speed, or whether the variability exceeded what automation could practically handle.

Technological Uncertainty

It was not known in advance whether a robotic system could achieve reliable grip and placement across the full range of part variation without excessive cycle time, or what gripper and vision configuration would be required.

Experimental Development

The team systematically tested combinations of adaptive gripper designs, vision-guided orientation detection, and motion planning strategies, measuring grip success rate, cycle time, and failure modes across representative part samples.

What Failed?

An initial rigid gripper with standard vision guidance achieved acceptable accuracy on regularly-shaped parts but failed to reliably grip parts at the extremes of the variation range, requiring redesign of the gripper mechanism itself.

Technological Advancement

The team developed a custom adaptive gripper combined with a refined vision-guided orientation algorithm that achieved reliable handling across the full part variation range, generating new technical knowledge about automating handling for this class of variable parts.

Potentially Relevant SR&ED Activities

  • Systematic testing of gripper designs against variable part geometry
  • Development and refinement of vision-guided orientation detection
  • Cycle time and reliability benchmarking across iterations

What Would Generally Not Qualify

Running the finalized automated system in production on typical part batches would be routine operation and would not itself qualify as further eligible development.

Documentation

Grip success rate data across gripper iterations, vision algorithm development notes, and cycle time benchmarking records would support this claim.
About The Author

Dale Doering

Dale Doering is the owner of SRED Consultants Inc., helping businesses navigate the complexities of Scientific Research and Experimental Development (SR&ED) claims. With a strong understanding of the technical and interpretive requirements of the SR&ED program, Dale works with companies to identify eligible projects, document technological challenges, and clearly demonstrate the systematic experimentation or analysis undertaken to achieve advancement. His approach focuses on translating complex technical work into well-supported SR&ED claims, helping clients maximize eligible opportunities while maintaining a clear understanding of the program’s requirements.

Recent Posts

Frequently Asked Questions

What core technological uncertainty did this SR&ED project address?

The project addressed whether standard robotics could handle highly variable parts at production speeds—specifically, if a combination of gripper design, vision guidance, and motion planning could achieve reliable grip and placement across full part variations without causing excessive cycle times.

The initial setup—which relied on a rigid gripper with standard vision guidance—worked on regularly shaped parts but failed to grip parts with extreme variations. This failure demonstrated that standard off-the-shelf equipment was insufficient and required custom engineering.

The team created a custom adaptive gripper paired with a refined vision-guided orientation algorithm. This generated new technical knowledge regarding automated handling strategies for non-uniform, variable-geometry industrial parts.

Eligible activities included the systematic testing of adaptive gripper designs against part geometries, the development and iteration of vision-guided algorithms, and cycle time/reliability benchmarking across experimental testing phases.

To support the claim, the company needed contemporaneous evidence such as grip success rate data, vision algorithm notes, and cycle time benchmarking. Conversely, running the finalized system in daily production is considered routine operation and does not qualify.

Related Post